Duckietown.jl
Duckietown.jl is an independent community project based on the Duckietown simulation environment. It is not an official Duckietown product and is not maintained by Duckietown.
A Duckietown lane-following-with-obstacles MDP, written in Julia as a POMDPs.jl problem — a native reimplementation of the decision layer of a gym-duckietown-based environment, validated against it decision by decision, including exact NumPy RNG streams, so a seeded episode reproduces bit for bit on the machine the evidence was produced on (x86-64, Julia 1.11.3, unfused multiply-add), re-established by every release-grade run. Machines whose codegen fuses a*b+c - Apple Silicon, Julia 1.12 everywhere, and whichever CPU a CI runner happens to be - drift at the last bits of a few derived read-backs (measured across seven CI lanes: at most 80 ULP; tolerated and documented in the suite; discrete decisions remain identical).
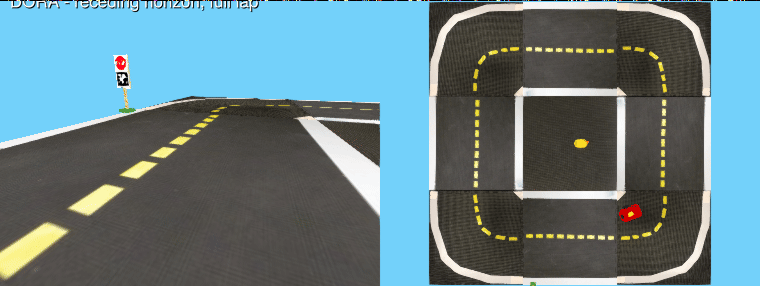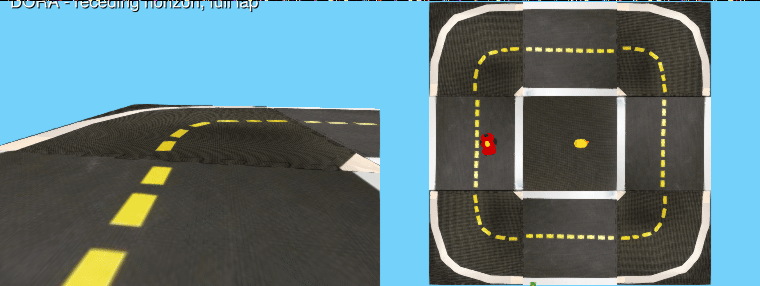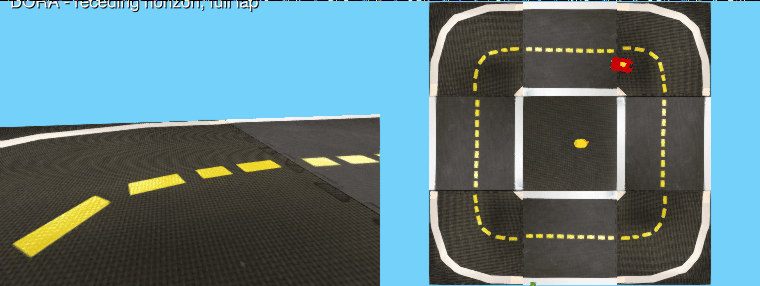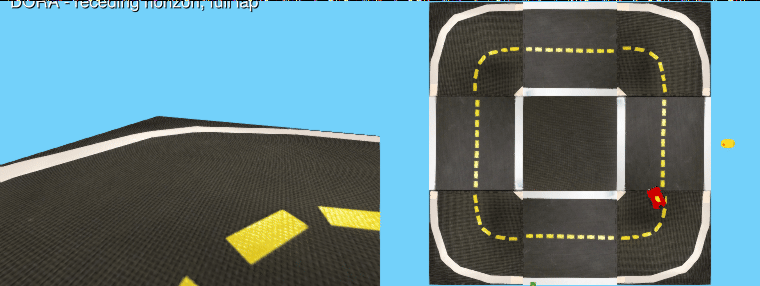
DORASolvers.jl under receding horizon completing a :stop_and_duck_safe lap, drawn by the package's own native renderer — solver, physics and renderer all in Julia. 2× speed; lookalike render, not parity evidence. Duckietown environment by the Duckietown Project.
Install
using Pkg
Pkg.add(url = "https://github.com/ai-vnv/Duckietown.jl")
using Duckietown loads no Python, no plotting library and no solver; the map is embedded in the package.
Quickstart
using Duckietown, POMDPs, Random

mdp = DuckietownMDP(scenario_config(:stop_and_duck_safe); action_space = :discrete)
s   = rand(MersenneTwister(1001), initialstate(mdp))
sp, r = @gen(:sp, :r)(mdp, s, FAST_STRAIGHT, MersenneTwister(7))
Scenarios (scenario_config): :lane_following (empty ring), :stop_and_duck (the source-default switches turned on, warts included), and :stop_and_duck_safe (the same world with the yield / stop-approach reward shaping switched on and the stop sign facing the traffic).
Running a planner
Any POMDPs.jl solver drives the model through the standard solve / action sequence:
using MCTS
planner = solve(MCTSSolver(n_iterations = 100, depth = 20), mdp)
a = action(planner, s)
For a full worked case study with an online SSP solver (DORASolvers.jl) — formulation, receding-horizon execution, and tile-by-tile replays of recorded laps — open the Pluto notebook notebooks/DORA_on_Duckietown.jl; notebooks/Playground.jl is the pick-a-solver starter.
Where to go next
- How it was built — what every file is, why it exists, and where each claim's evidence lives, under an explicit provenance rule.
- Validation record — the gate-by-gate evidence behind every "validated" statement.
- API (sidebar) — the exported surface, one page per layer, from the docstrings.
Acknowledgments
The environment semantics reimplemented here originate from the Duckietown Project: the hardware/software used for the experiments was developed by the Duckietown Project — www.duckietown.org. The reference textures and meshes are not redistributed by this package.